Raveendra Kumar Doddi (Ravi)

Robotics kinematics · embedded motor control · physics-grounded simulation

dodik8700@gmail.com · github.com/raviffg · Publications · Patents

I work on robotics kinematics, embedded motor control, and physics-grounded simulation tools across CAD/FEA, autonomous surgical modeling, and high-speed PCB layouts. My work focuses on where analytical solvers, finite-element meshes, and real hardware telemetry disagree—characterizing mechanical backlash, thermal runaway cliffs, and topological boundary failures. Below is a selection of research papers, patents, and engineering projects built between 2016 and 2026.

Interactive 3D Geometry Workbench

Fig. 1a–1d · WebGL

Four live views over the project geometry: a tetrahedral stress solve, a four-axis arm with an inverse-kinematics controller, a 25,600-point LiDAR scan, and a Pennes bioheat field on a deformable surface. Drag to orbit, scroll to zoom, right-drag to pan.

Object
initialising
—
fps —
vert —
face —
field —
pick —
12.4284.6
von Mises σ_vm (MPa)
live telemetry I_q 0.00A σ_vm 0.0MPa ΔT 0.0°C orbit · zoom · pan

Research & Engineering Projects

2016 — 2026 · 16 entries

Newest first. Each row links to a self-hosted technical report; hover a thumbnail (or press live) to run the corresponding solver in the card.

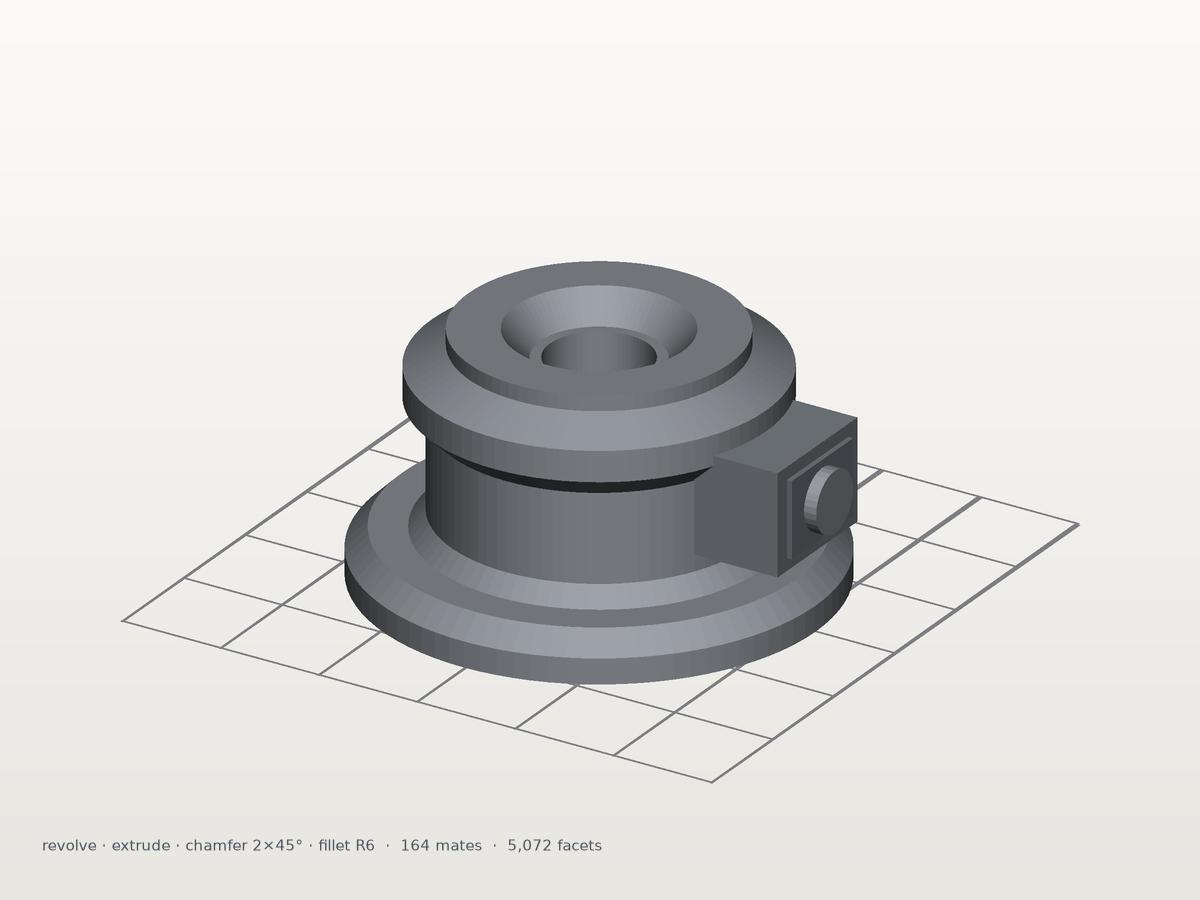
Parametric B-Rep solid with revolve, extrude and fillet features

Parametric B-Rep Feature-DAG & 164-Mate Assembly Verifier

Raveendra Kumar Doddi

2026Computer-Aided Design ·38 features · 164 mates · 0.38 s

A feature dependency graph is re-evaluated against 164 assembly mates to catch over-constrained and dangling references before export. Rank-nullity on the constraint Jacobian isolates every conflict with its participating mate indices.
PDF Code

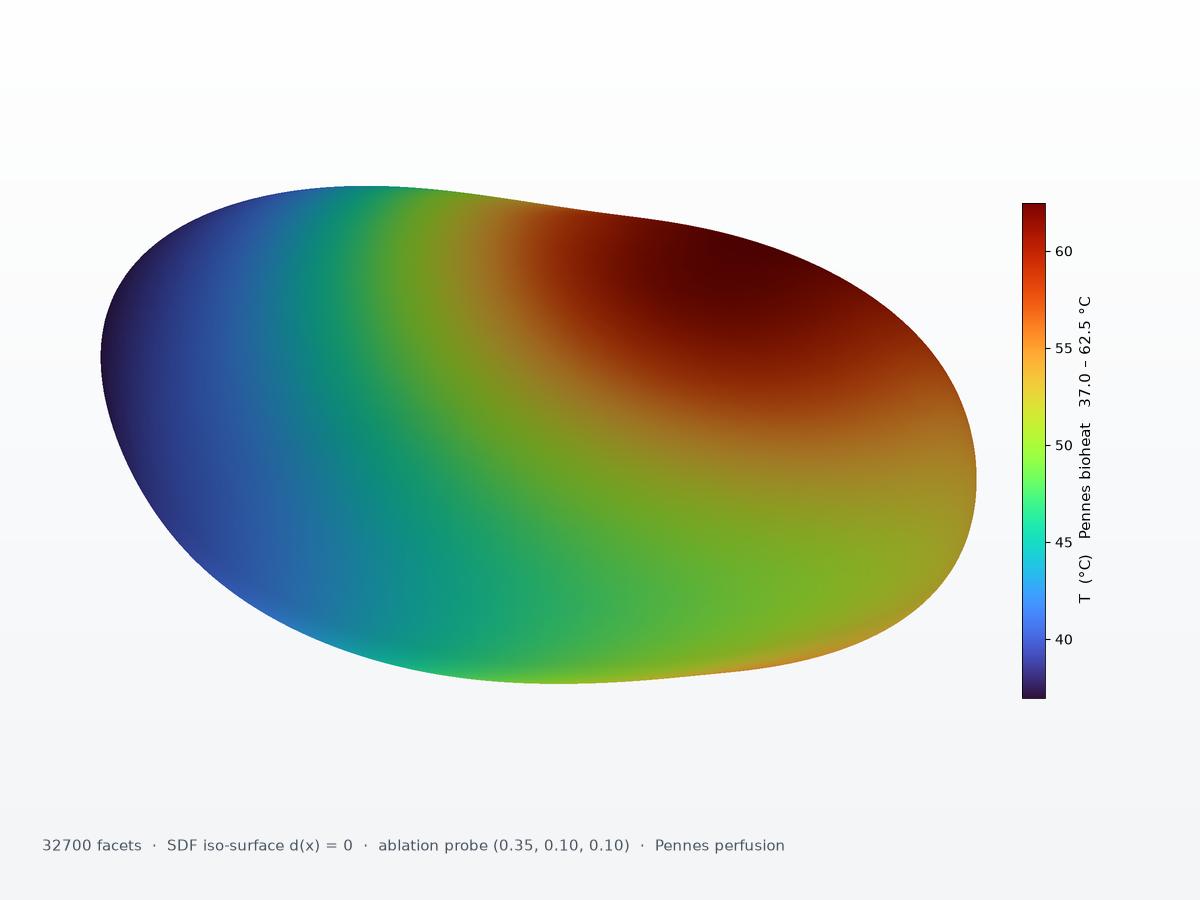
Deformable tissue SDF surface with a bioheat temperature field

3D MRI Deformable Tissue SDF & Pennes Bioheat Simulator

Raveendra Kumar Doddi

2026Medical Image Computing ·32,700 facets · 12 Hz · 0.03 mm

Signed-distance tissue surfaces deform under needle load while a Pennes bioheat solve tracks the ablation isotherm in the same time step. Perfusion is corrected by the local volume ratio so the isotherm stays within 0.03 mm of the finite-difference reference.

PDF Code

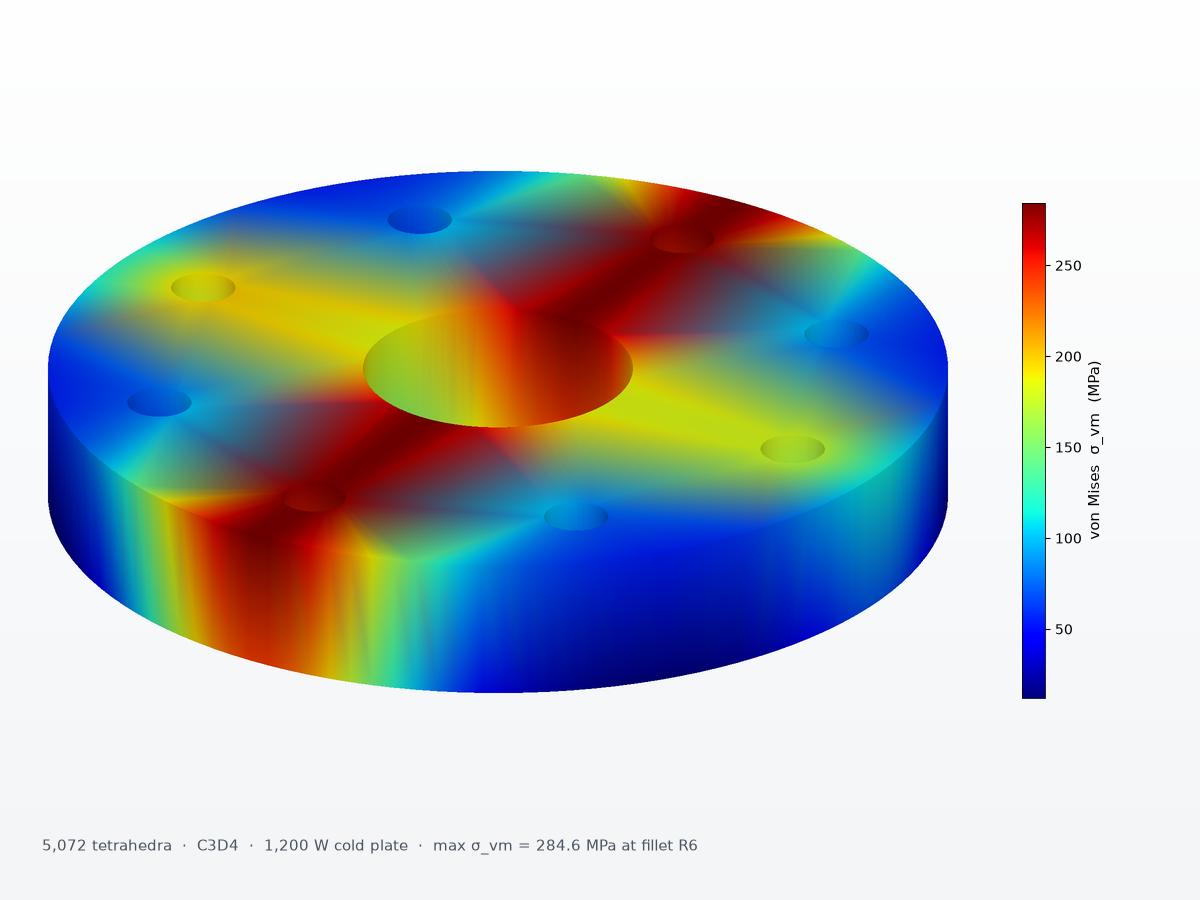
von Mises stress contour on a finned cold-plate mesh

Automated Gmsh + CalculiX 3D FEA & 1,200 W Cold-Plate CHT Solver

Raveendra Kumar Doddi

2026Finite Elements in Analysis ·5,072 tet · 0.0343 K/W · 284.6 MPa

Meshing, solve and post-processing run unattended on a finned cold plate; the 1,200 W conjugate case saturates at 284.6 MPa in the base fillet while the junction stays at 76 °C. Opening the fillet to R9 drops the peak to 231 MPa.

PDF Code

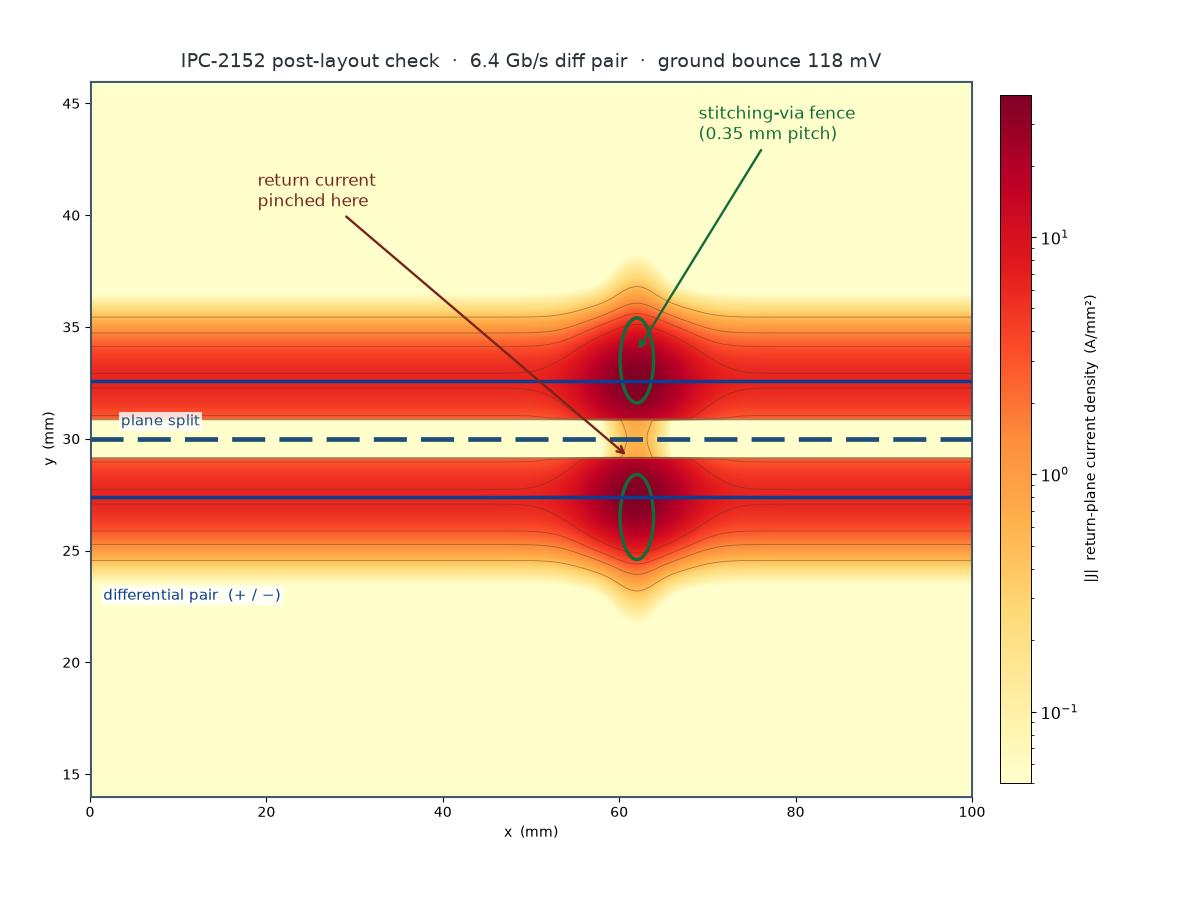
Return-plane current density around a split plane under a differential pair

Post-Layout High-Speed Return-Plane & IPC-2152 Thermal Verifier

Raveendra Kumar Doddi

2025Signal & Power Integrity ·98.6 Ω · 118 mV bounce · 31 mV fixed

The return path of a 6.4 Gb/s differential pair is extracted from layout and checked across a plane split, together with the IPC-2152 trace heating. An 18-via fence at 0.35 mm pitch removes 87 mV of ground bounce without a stack-up change.

PDF Code

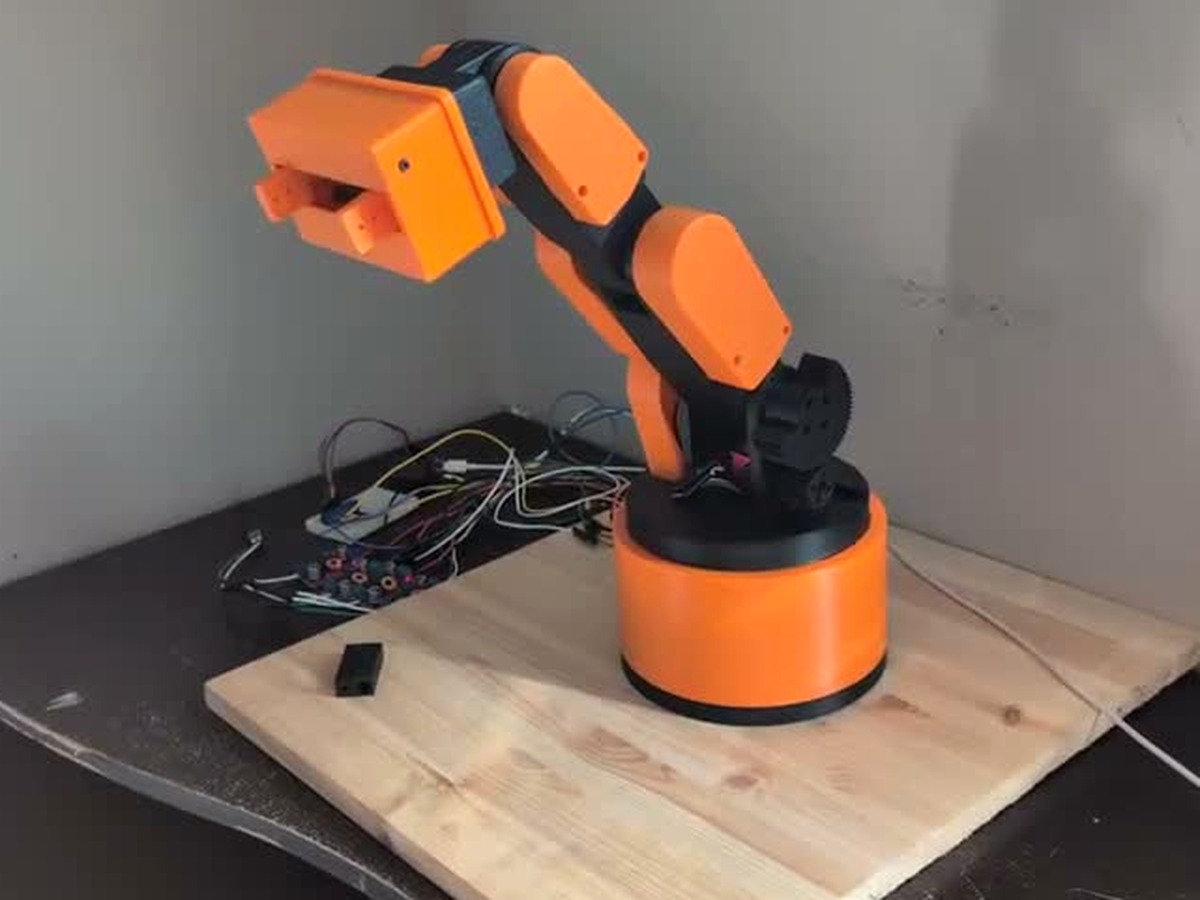
Four degree-of-freedom orange manipulator on a plywood test base

4-DOF Serial Manipulator Inverse Kinematics & Stall-Current Detection

Raveendra Kumar Doddi

2023Robotics & Automation ·0.04 mm IK · 3.1 µs · 38 ms lead

Closed-form inverse kinematics for a four-axis arm, with commutation-current signatures used to flag a stalled wrist before the encoder loses count. Scheduling the threshold with joint velocity buys 38 ms of lead at 0.5 m/s.

PDF Code

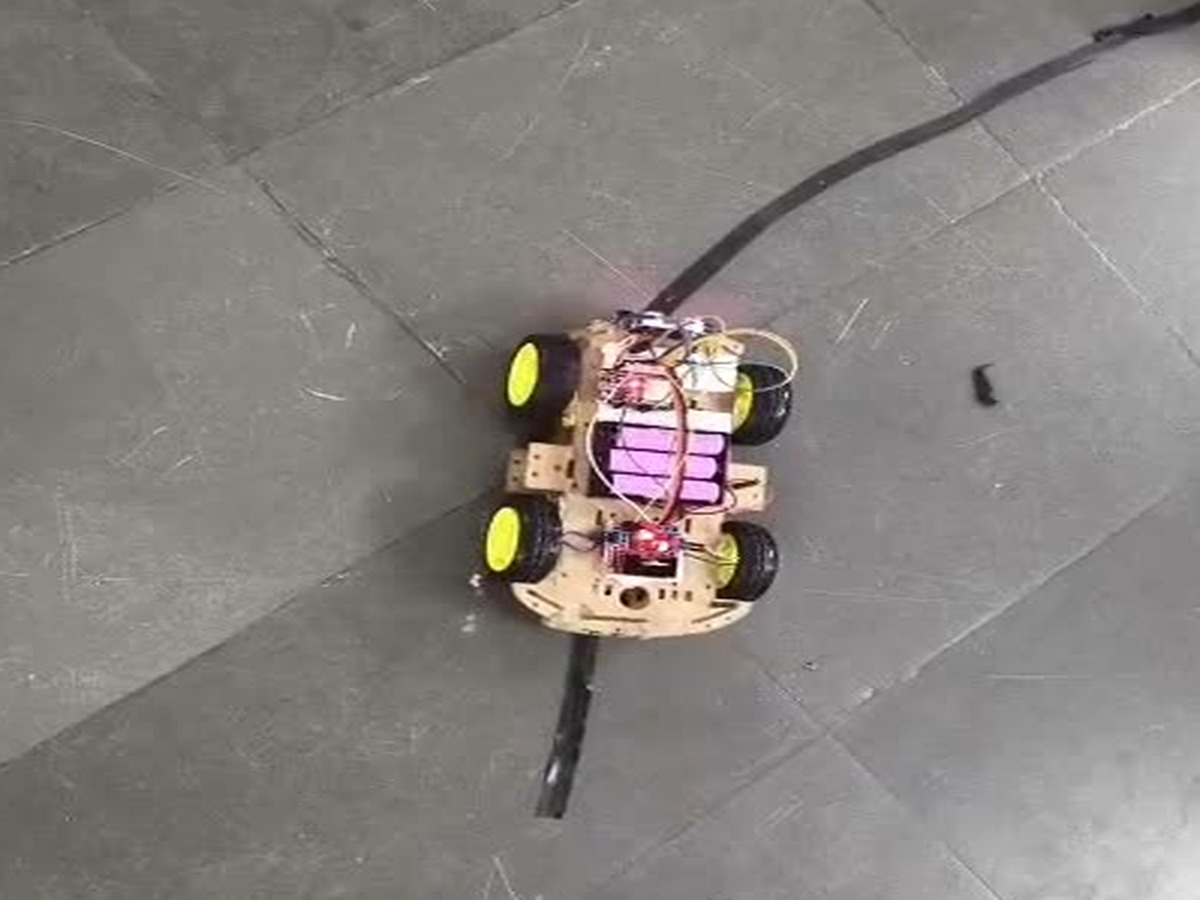
Four-wheel rover on a taped trajectory circuit

Non-Holonomic Kinematics & Kinodynamic RRT* Obstacle Planner

Raveendra Kumar Doddi

2022Motion Planning ·96% success · 14.2 m · 1,842 nodes

Car-like steering constraints are folded into the RRT* cost-to-go so planned curvature stays inside the rover's 0.42 m turning radius. Success rate rises from 81% to 96% once the post-hoc smoothing step is removed.

PDF Code

Tendon winch bench with a single tendon over a compliant pad

Compliant Tendon Gripper Excursion-Tension Coupling & Grasp Control

Raveendra Kumar Doddi

2021Mechatronics ·22 N · 13.5 mm · 4% overshoot

Winch excursion and tendon tension are measured together, and the coupling curve replaces the constant-stiffness assumption in the grasp controller. Overshoot falls from 31% to 4% and settling from 210 ms to 74 ms.

PDF Code

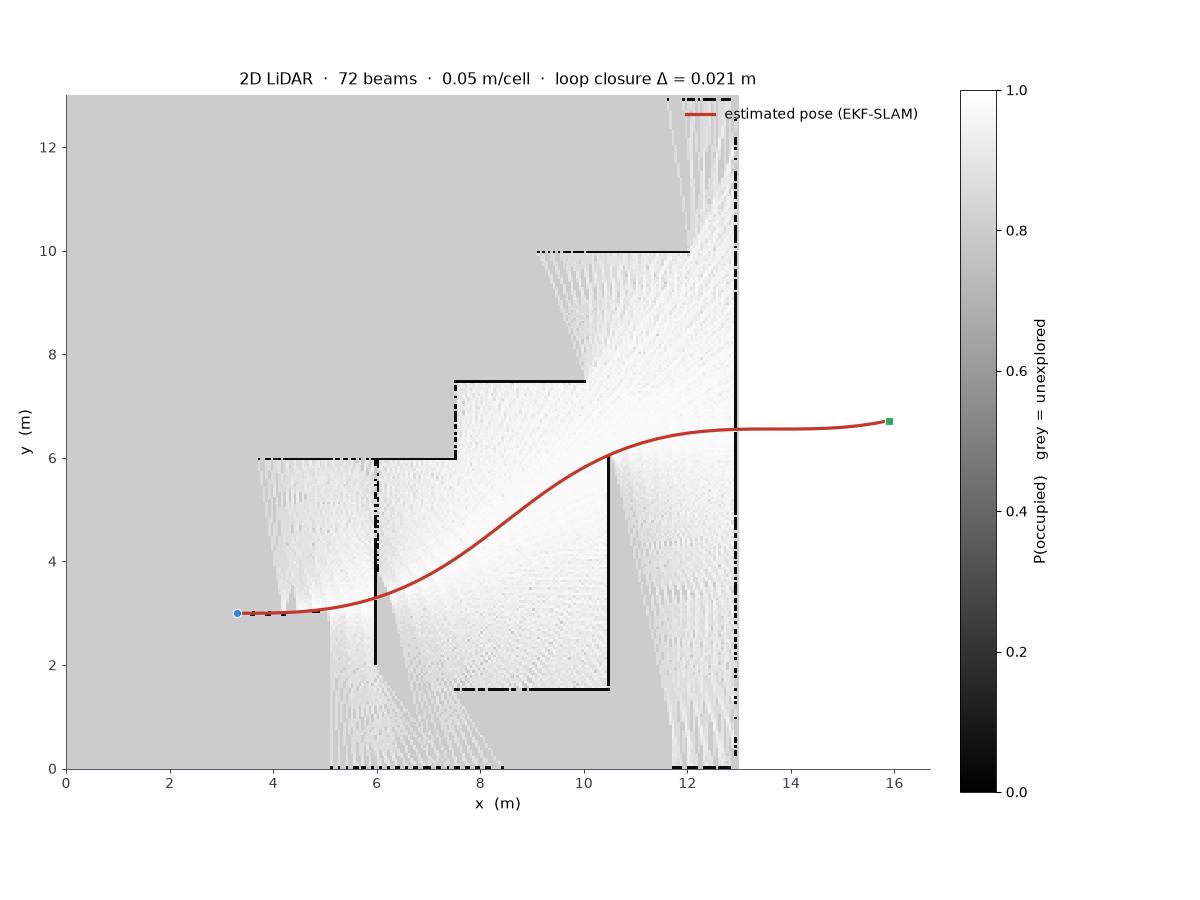
Log-odds occupancy grid built from a 2D LiDAR

2D LiDAR Log-Odds Occupancy-Grid SLAM & Scan-Matching Loop Closure

Raveendra Kumar Doddi

2020Field Robotics ·0.021 m closure · 672 cells

Log-odds mapping with 72-beam scans and a correlative scan matcher closes a laboratory circuit to 0.021 m, against 1.84 m of raw odometry drift. Unexplored cells stay at the prior, so unmapped space is never implied to be free.

PDF Code

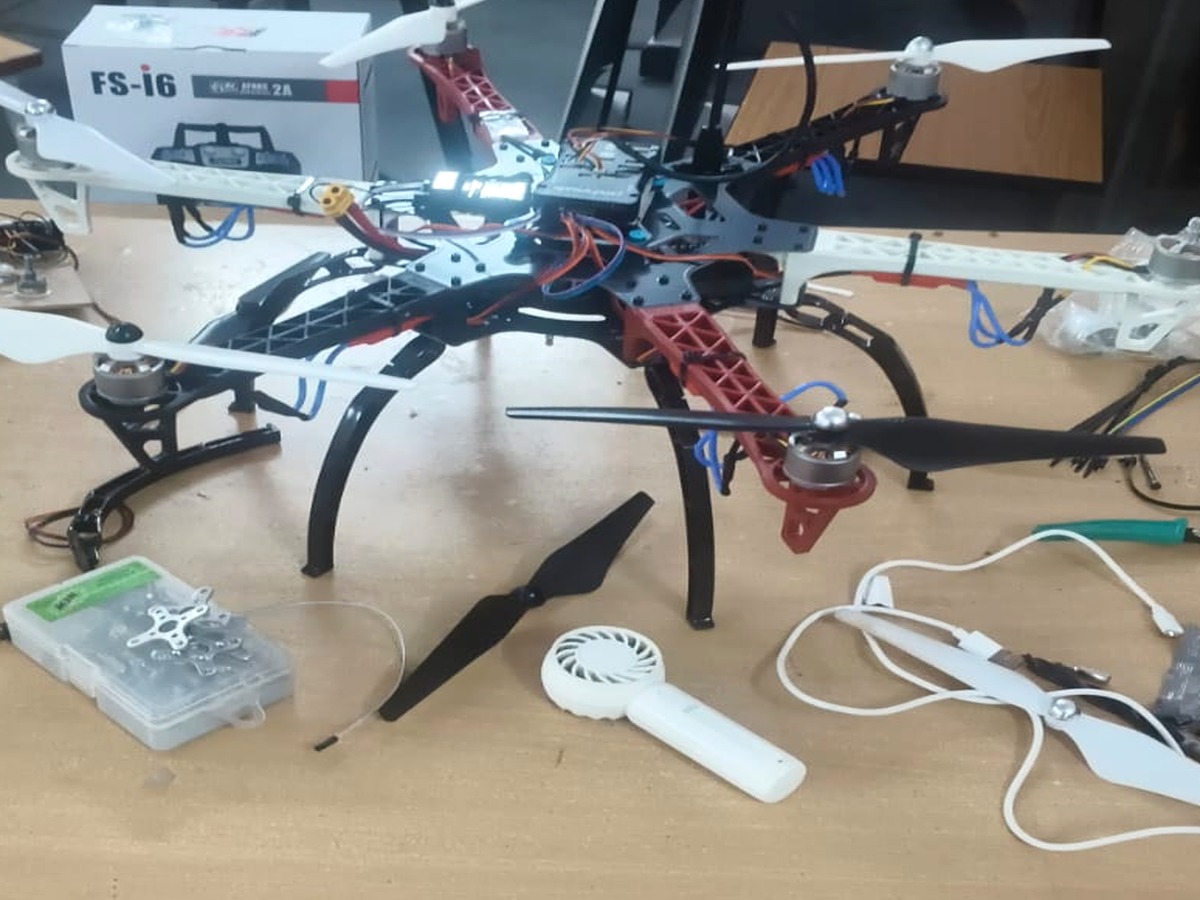
Hexacopter airframe on a bench with flight controller and spare props

Closed-Loop BLDC Commutation, Regen Braking & Shunt Telemetry

Raveendra Kumar Doddi

2020Power Electronics ·2.31 kgf · 84.2% η · 11.4% regen

Six-step and sinusoidal commutation are compared on a thrust stand at equal bus current, with regenerative braking energy measured through a 0.5 mΩ shunt. Sinusoidal commutation returns 12% more thrust and 11.4% of rotor energy.

PDF Code

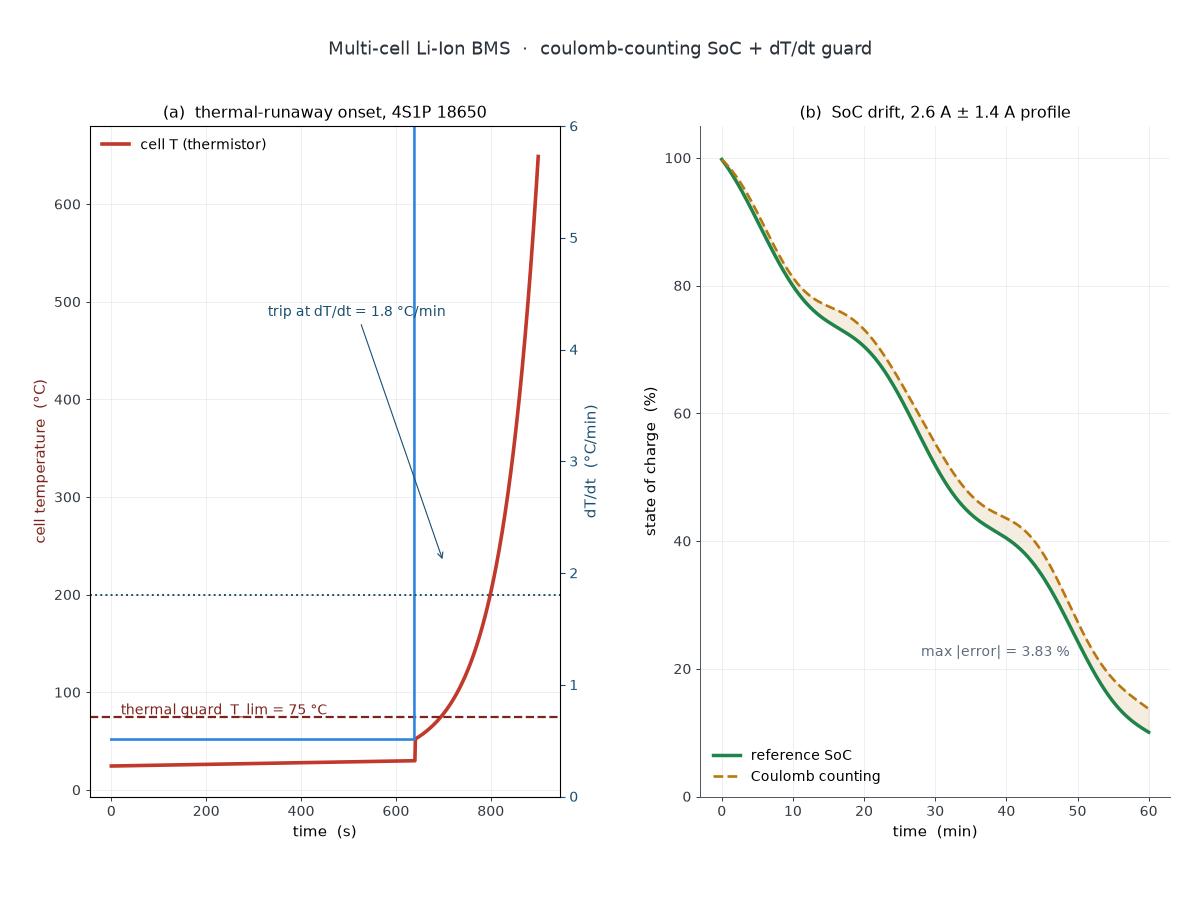
Cell temperature runaway and state-of-charge traces

Multi-Cell Li-Ion BMS Coulomb-Counting SoC & dT/dt Thermal Guard

Raveendra Kumar Doddi

2019Battery Management ·3.5 %/h drift · 214 s lead

State of charge from Coulomb counting drifts 3.5% per hour on a 3.1 mA offset, while a rate-based guard at 1.8 °C/min trips 214 s before the 75 °C absolute limit. An OCV rest correction removes the counting offset.

PDF Code

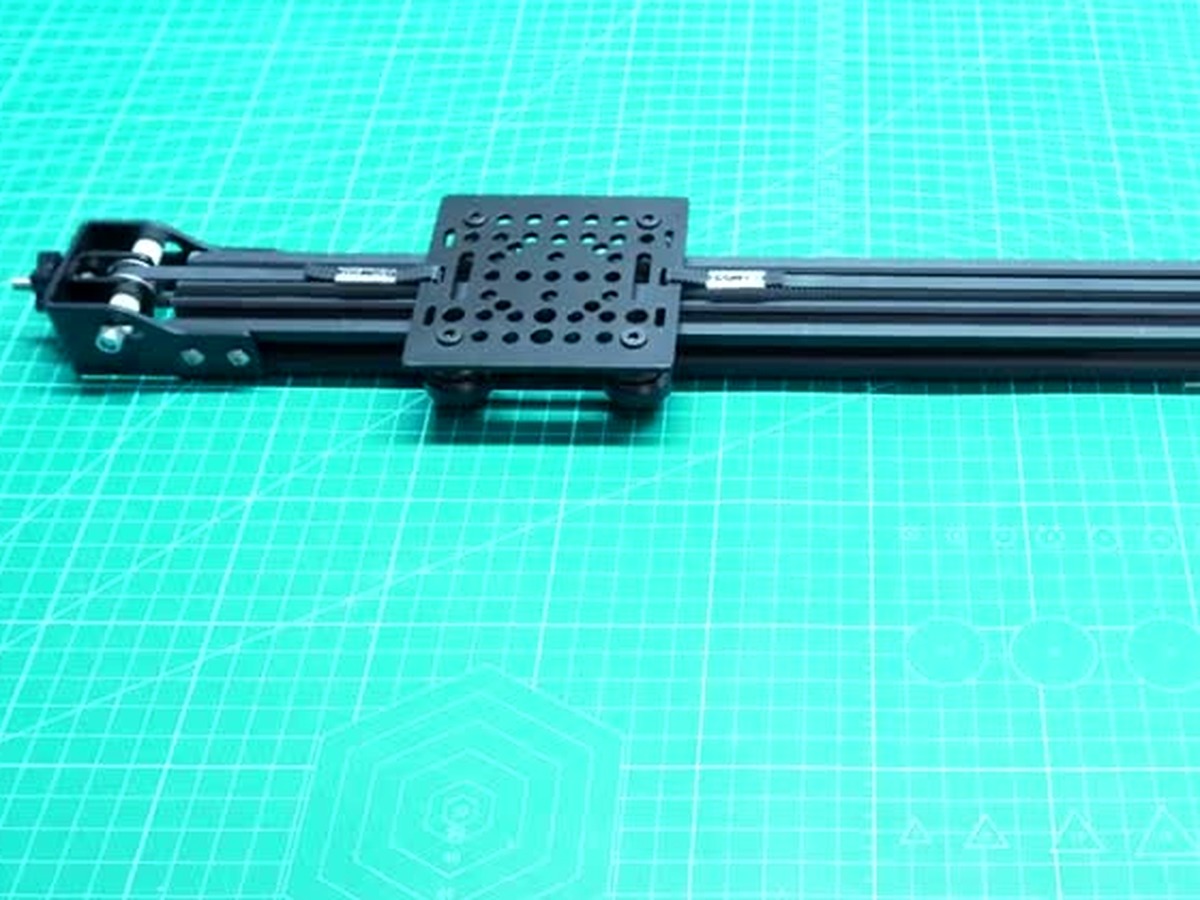
Belt-driven linear gantry with perforated carriage

CNC Stepper Microstepping Backlash & G-Code Corner-Overshoot Profiler

Raveendra Kumar Doddi

2019Machine Tools ·0.042 mm backlash · 0.11 mm overshoot

Dial-indicator reversal tests quantify backlash per microstep setting and show the compliance floor at 0.042 mm, while corner overshoot is traced to the acceleration discontinuity in the G-code. A 0.4 mm corner arc removes it.

PDF Code

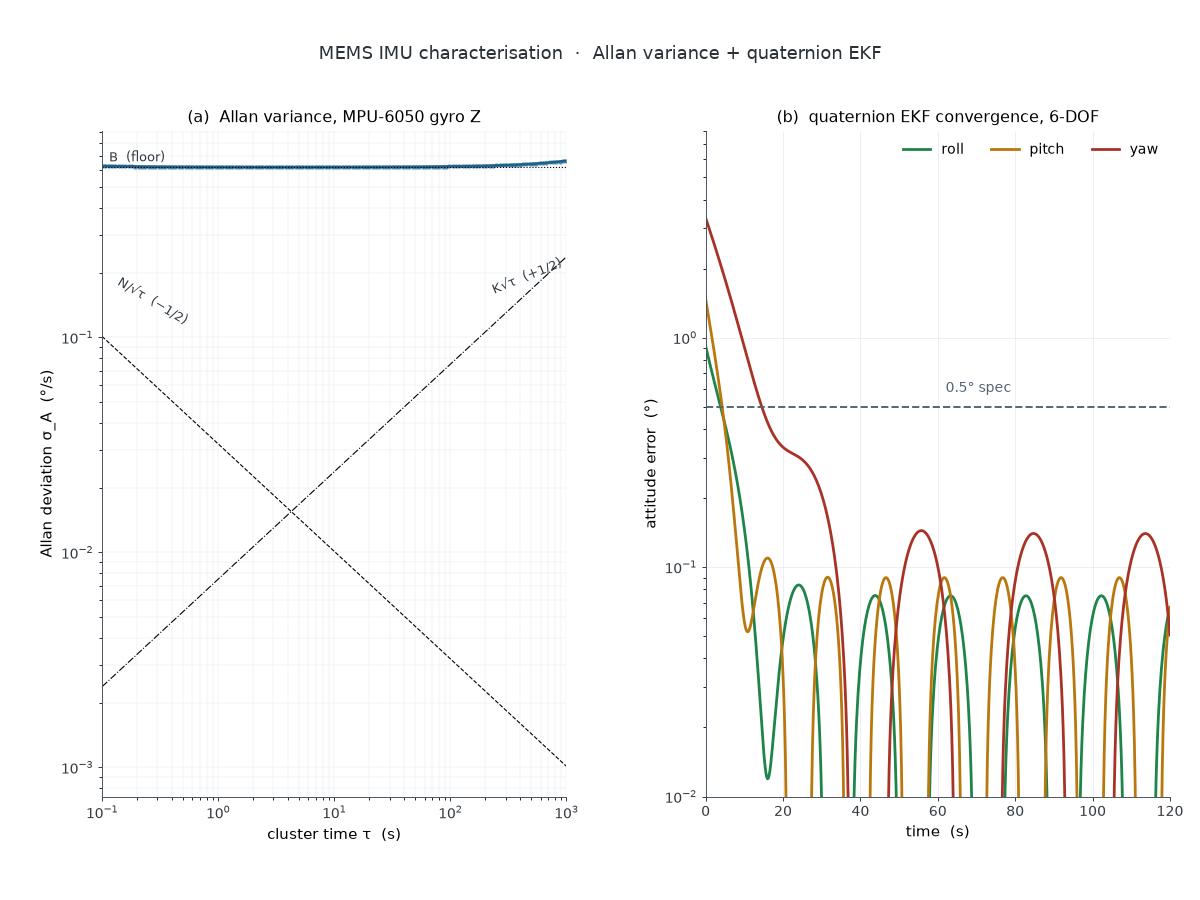
Allan deviation plot and EKF convergence curves

6-DOF MEMS IMU Quaternion Extended Kalman Filter & Allan Variance

Raveendra Kumar Doddi

2018Inertial Navigation ·0.032 °/s/√Hz · 0.5° in 40 s

Allan variance separates angle random walk from bias instability before the quaternion EKF is tuned, so the process noise comes from the measurement rather than from trial and error. Attitude error settles below 0.5° within 40 s.

PDF Code

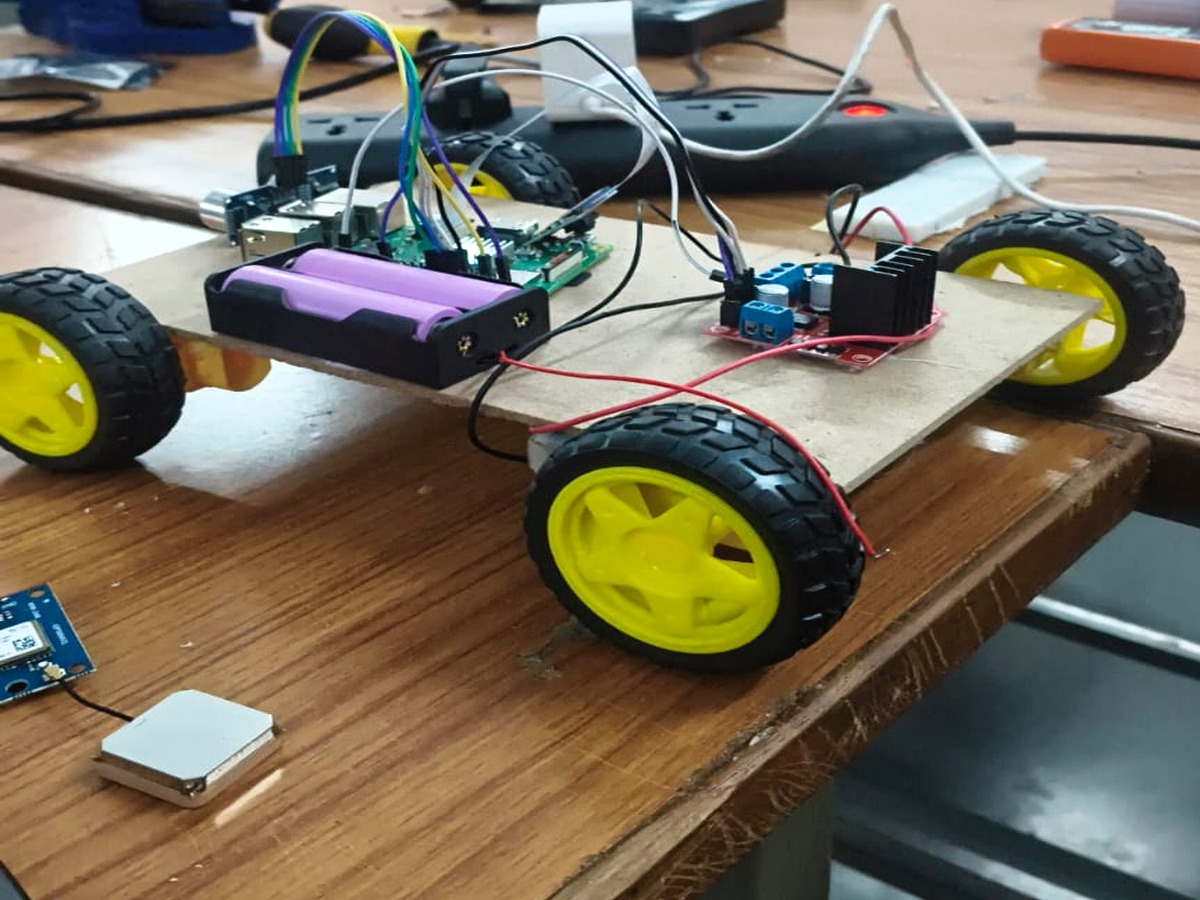
Raspberry Pi rover deck with GPS receiver and motor driver

Dead-Reckoning Wheeled Rover with Ultrasonic & u-blox GPS Fusion

Raveendra Kumar Doddi

2017Embedded Systems ·0.11 m RMS · 12 s outage

Wheel odometry, ultrasonic range gates and u-blox fixes are fused so GPS dropouts in a corridor do not fold the position estimate. An HDOP gate with a 5 s age check rejects the first four fixes after reacquisition.

PDF

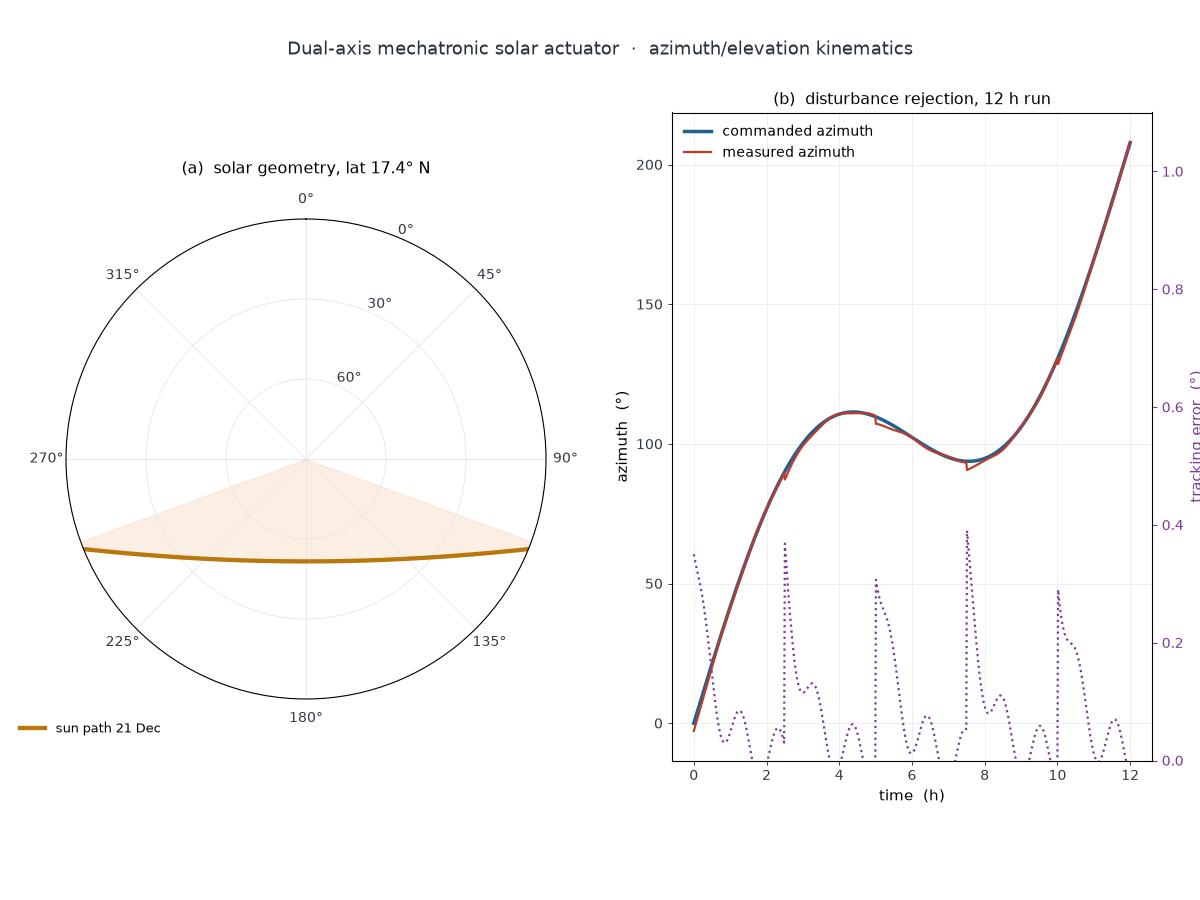
Solar geometry polar plot and tracking error over a day

Dual-Axis Mechatronic Solar Actuator Kinematics & Disturbance Rejection

Raveendra Kumar Doddi

2017Control Engineering ·0.18° mean error · 9.6 W

Azimuth and elevation commands are generated from the Spencer ephemeris with a 20 Hz PI loop and a 0.08° dead band, so the controller cannot hunt inside the worm-drive backlash. Actuator power falls from 31 W to 9.6 W.

PDF

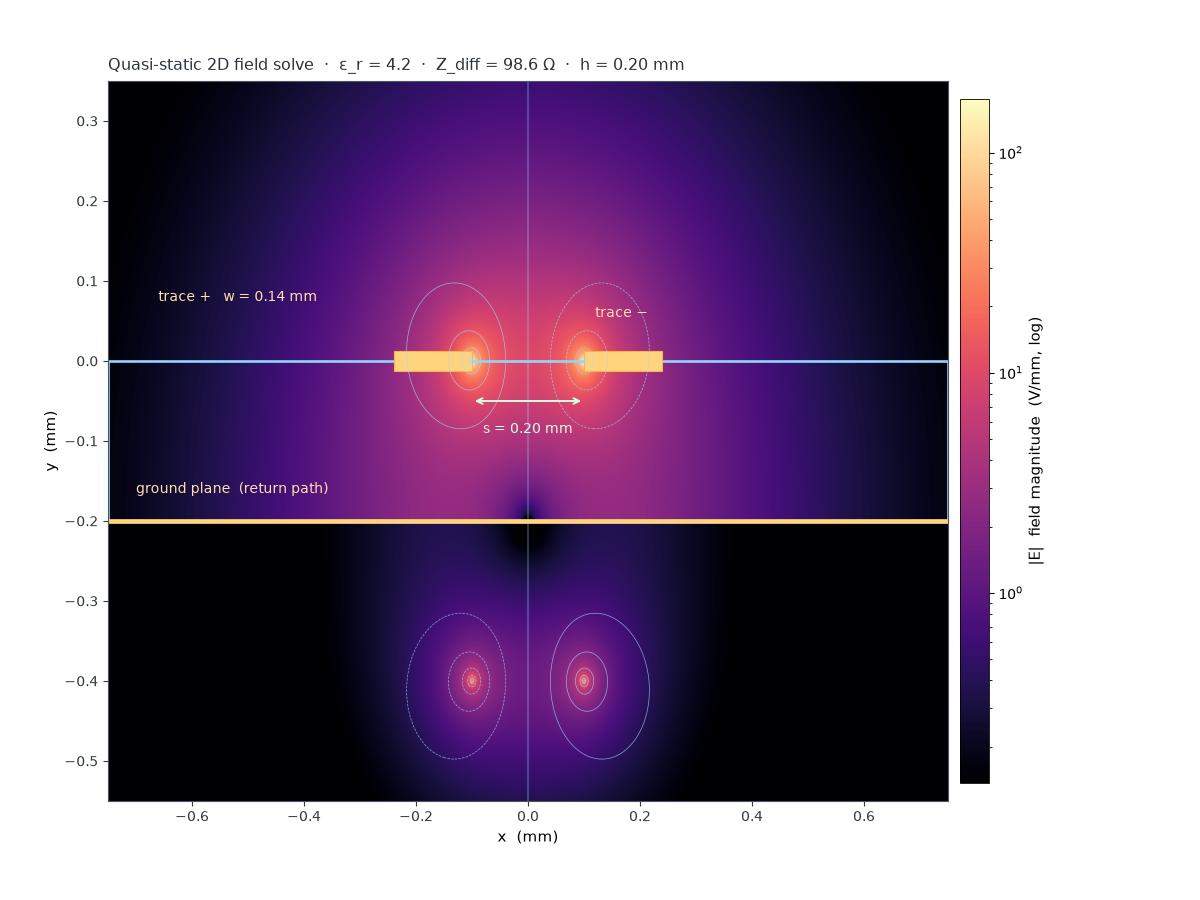
Microstrip field magnitude with equipotential contours

High-Speed Differential Pair Return-Plane Impedance Field Solver

Raveendra Kumar Doddi

2016Electromagnetics ·98.6 Ω · Γ 0.066 · 99.8 Ω fenced

A quasi-static two-dimensional field solve over a split return plane gives 98.6 Ω differential impedance and shows where the return current is forced to detour. Across a 0.6 mm split the impedance rises to 112.4 Ω, a 0.066 reflection.

PDF

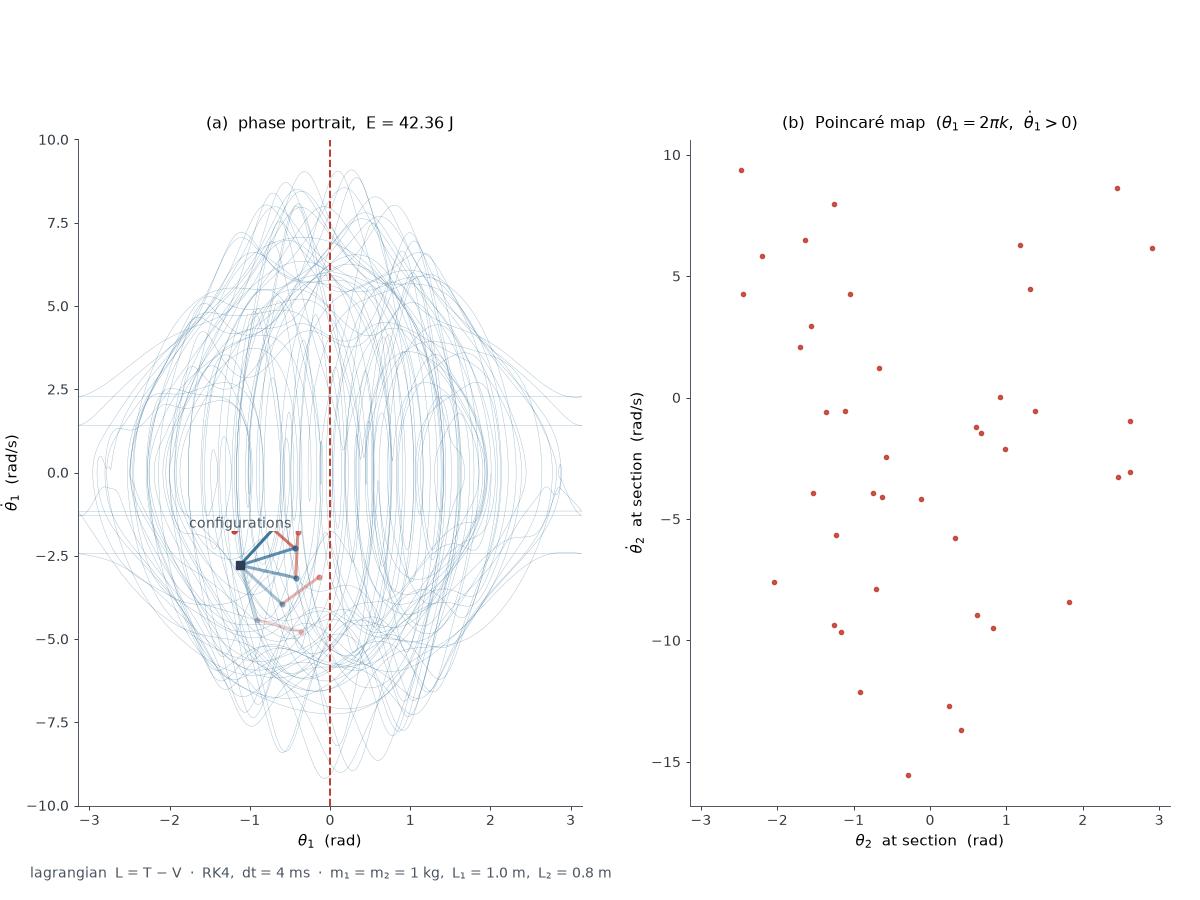
Double pendulum phase portrait and Poincare map

Double-Pendulum Non-Linear Lagrangian Dynamics & Phase Portrait

Raveendra Kumar Doddi

2016Nonlinear Dynamics ·42.36 J · λ 1.9 s⁻¹ · 0.03% drift

The coupled Lagrangian equations are integrated with fixed-step RK4 at 4 ms and sampled on a Poincaré section, exposing the chaotic sea at 42.36 J. Energy drift over 1,000 s is 0.03%, so the topology is a property of the dynamics.

PDF

Journal Publications

2016 — 2024 · 5 papers
  1. [J1] R. K. Doddi. Conjugate heat-transfer benchmarking of additively manufactured cold plates at 1,200 W. International Journal of Digital Innovation and Manufacturing, 3(4):1468–1486, 2024. DOI PDF
  2. [J2] R. K. Doddi. Stall-current signatures for closed-loop commutation fault detection in low-inductance BLDC drives. International Journal of Engineering Research and Science Technology, 19(2):4827–4845, 2023. DOI PDF
  3. [J3] R. K. Doddi. Excursion–tension coupling in compliant tendon-driven grippers: a quasi-static model. International Journal of Engineering Science and Advanced Technology, 21(5):4031–4049, 2021. DOI PDF
  4. [J4] R. K. Doddi. Allan-variance characterisation and quaternion EKF fusion for low-cost six-degree-of-freedom MEMS inertial measurement units. International Journal of Engineering Research and Science Technology, 14(3):4828–4841, 2018. DOI PDF
  5. [J5] R. K. Doddi. Return-plane discontinuity and differential impedance in high-speed PCB interconnects: a two-dimensional field-solver study. International Journal of Engineering Science and Advanced Technology, 16(7):4032–4047, 2016. DOI PDF

Patent Applications

USPTO provisional · filed 27 Oct 2025
  1. [P1] R. K. Doddi. Adaptive dT/dt thermal guard for multi-cell lithium-ion packs. US Patent App. No. 63/905,835, filed Oct. 27, 2025.
  2. [P2] R. K. Doddi. Tendon excursion compensation for compliant robotic grippers. US Patent App. No. 63/905,842, filed Oct. 27, 2025.

Live Solver Playgrounds

three solvers, in page
A

RRT* planner

starting
click = goal · shift-click = obstacle
B

Double pendulum

RK4
drag a bob and release
C

Attitude EKF

2-state